Robotics
Line-Following Robot Platform
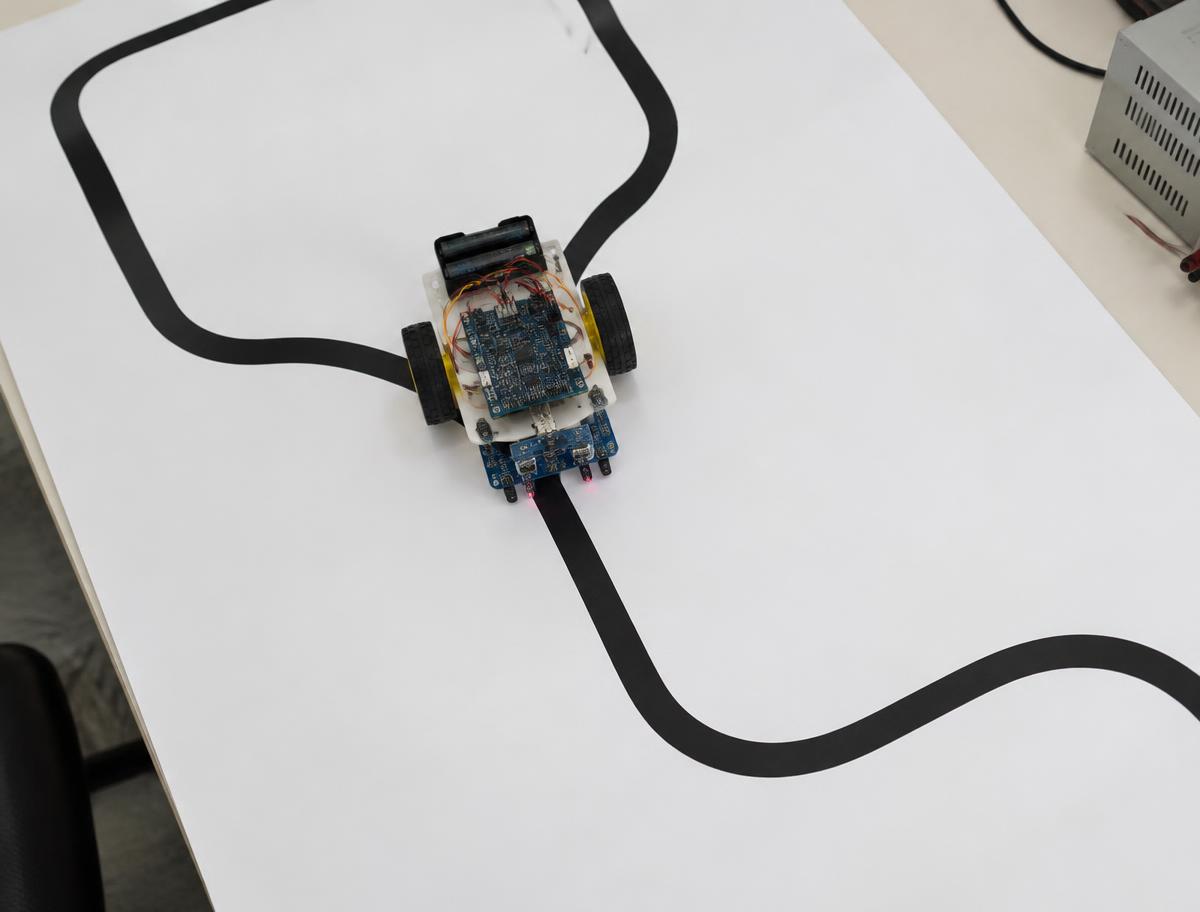
A two-wheel differential-drive robot that tracks a line using an infrared sensor array and PID control.
This is sample content for development and does not describe a completed GCURC project.
 Illustrative image
Problem
New members need a hands-on platform for learning sensing, control loops and motor driving before joining larger builds.
Objectives
- Follow a black line reliably on a white track.
- Tune a PID controller and document the effect of each gain.
- Produce a reusable chassis and wiring guide for training sessions.
Intended users
First-year members and workshop participants.
System architecture
Five-channel IR reflectance array → microcontroller (PID loop) → dual H-bridge motor driver → DC gear motors.