Robotics
Desktop Robotic Arm
A 4-degree-of-freedom servo arm with a gripper, used to study kinematics and pick-and-place routines.
This is sample content for development and does not describe a completed GCURC project.
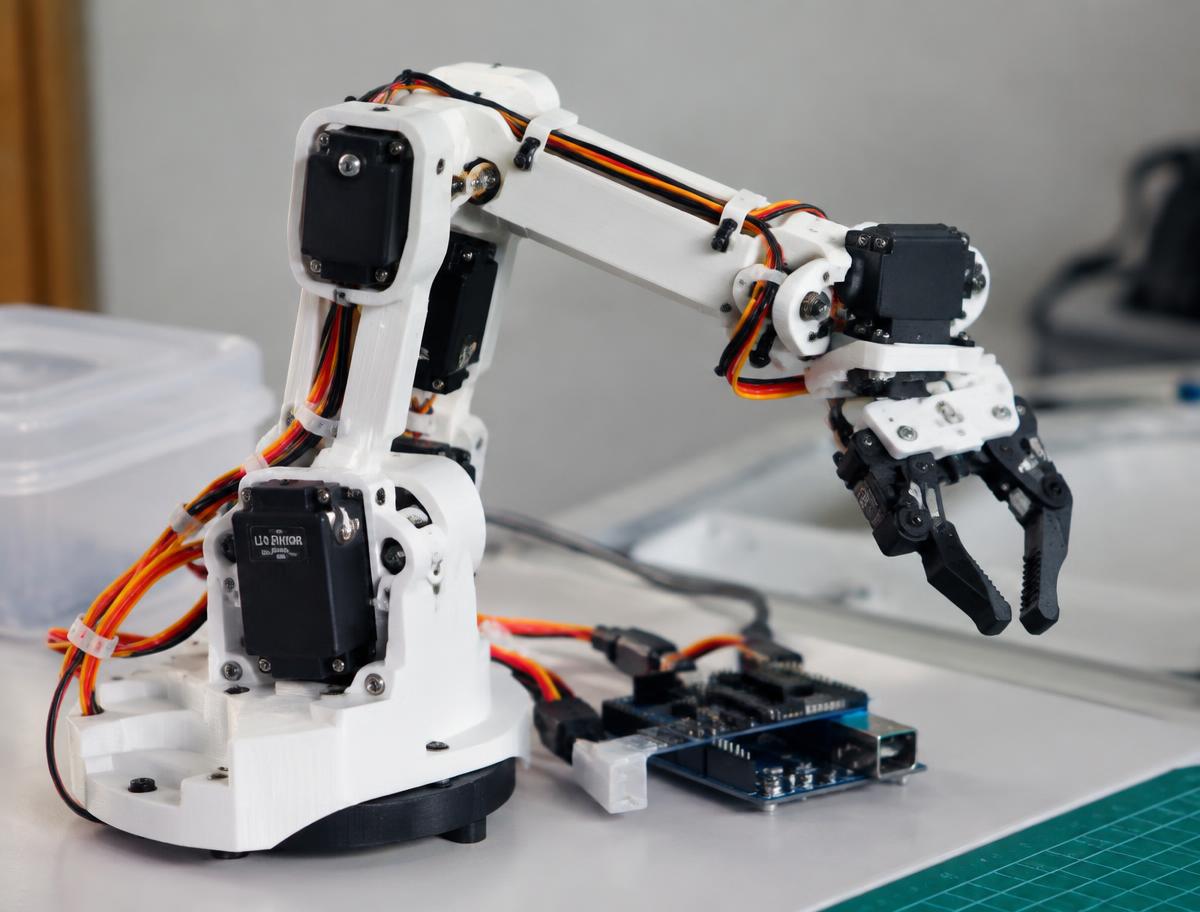 Illustrative image
Problem
Students rarely get to experiment with manipulator kinematics on physical hardware.
Objectives
- Design and print arm links.
- Implement inverse kinematics for target positions.
- Demonstrate a repeatable pick-and-place task.
Intended users
Members interested in mechatronics and mechanical design.
System architecture
Host PC computes joint angles → serial link → microcontroller → PWM servo control.